Control Systems Trainers, IDR 20 million per unit.
Rotary inverted pendulum, linear inverted pendulum, ball and beam, birotor. Built in Yogyakarta, ready to ship. Students write the controller themselves in C, Python or Simulink.
INCLUDED: plant · controller board · PSU · cables · lab manual · source code · 1-year warranty · ready stock
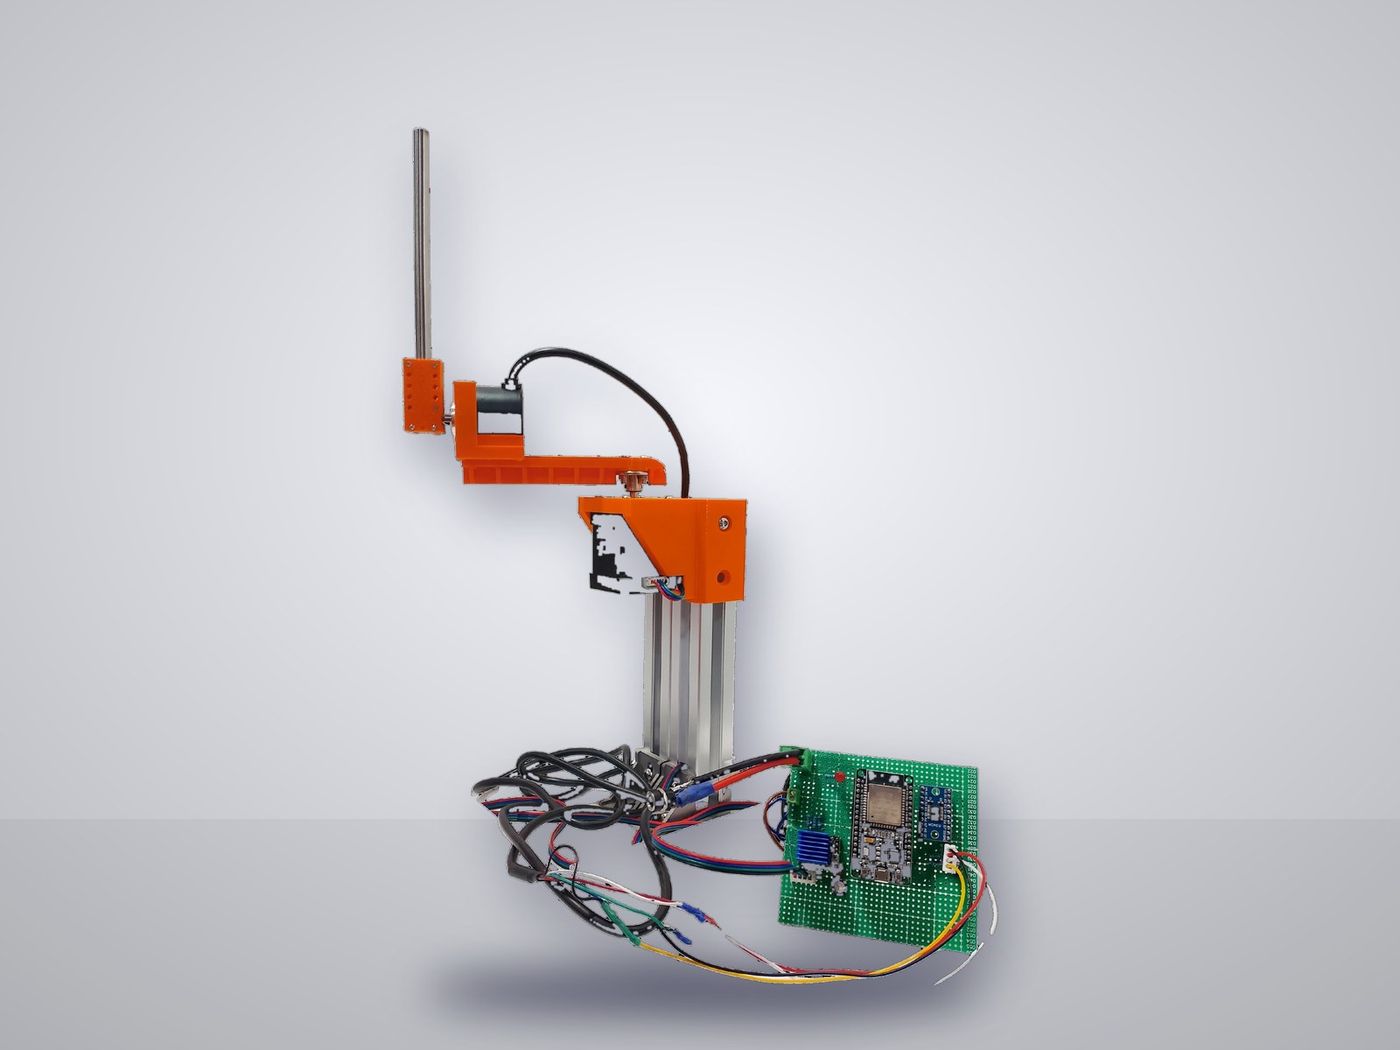
A rod balanced on the tip of a rotating arm.
The Furuta pendulum. The arm rotates in the horizontal plane; the pendulum hangs from its tip and must be held upright. Two encoders, one motor, four states. Students begin with a swing-up and stabilise with PID, then move to state feedback.
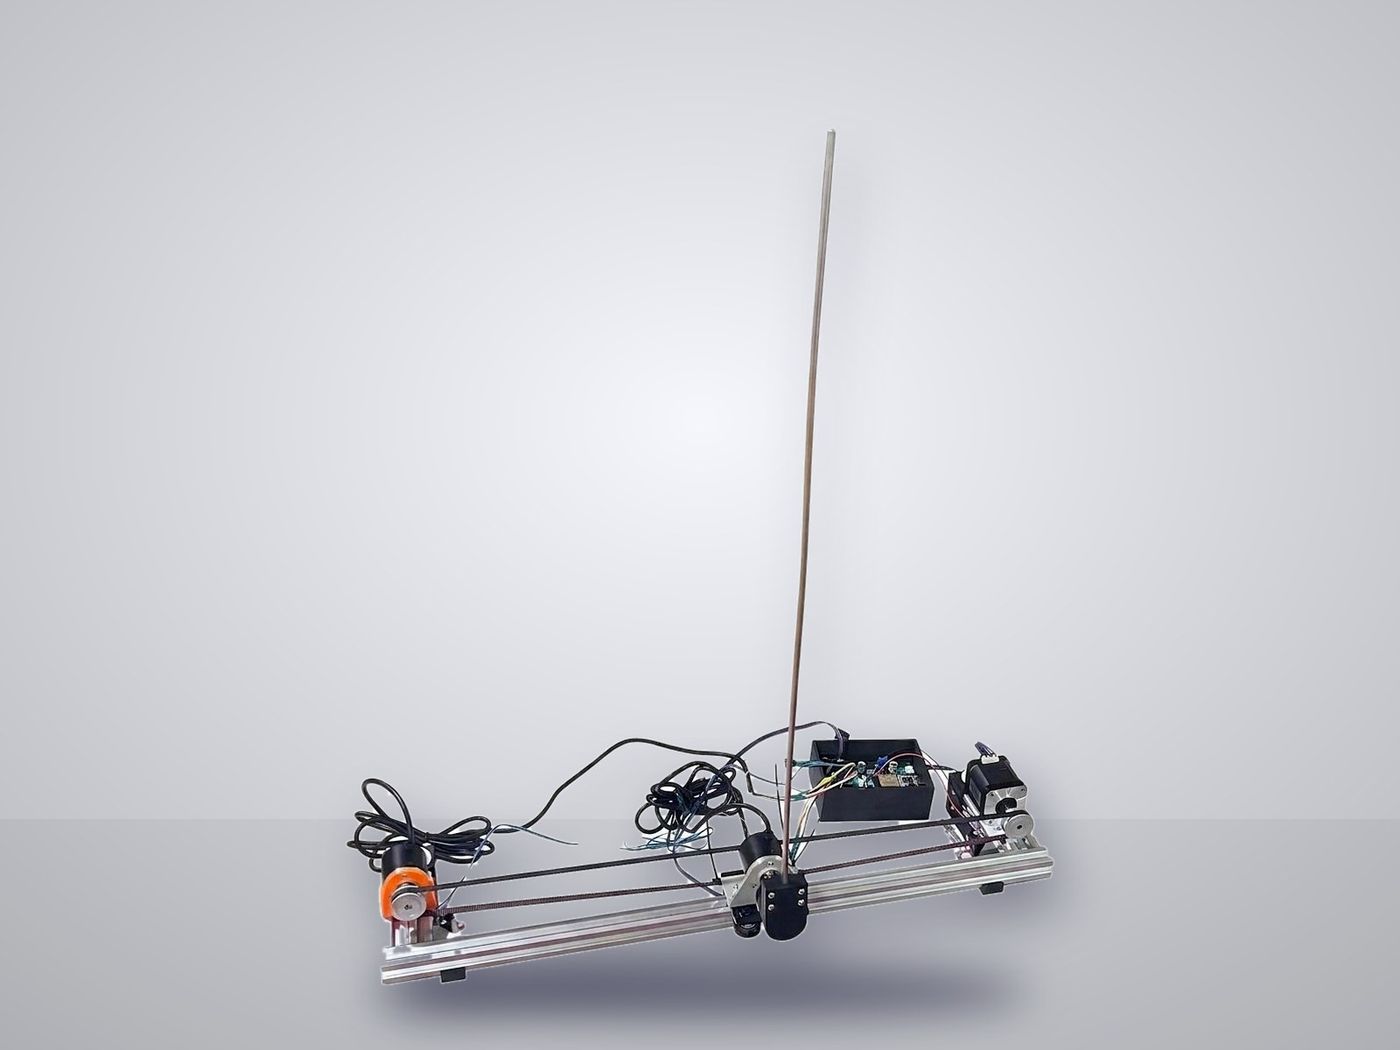
A cart on a rail, a pole that wants to fall.
The cart-pole. Two tasks at once: keep the pole upright and bring the cart to a position. A PID loop on the pole angle alone lets the cart drift to the end of the rail, which is the lesson. Full state feedback holds both. Try it.
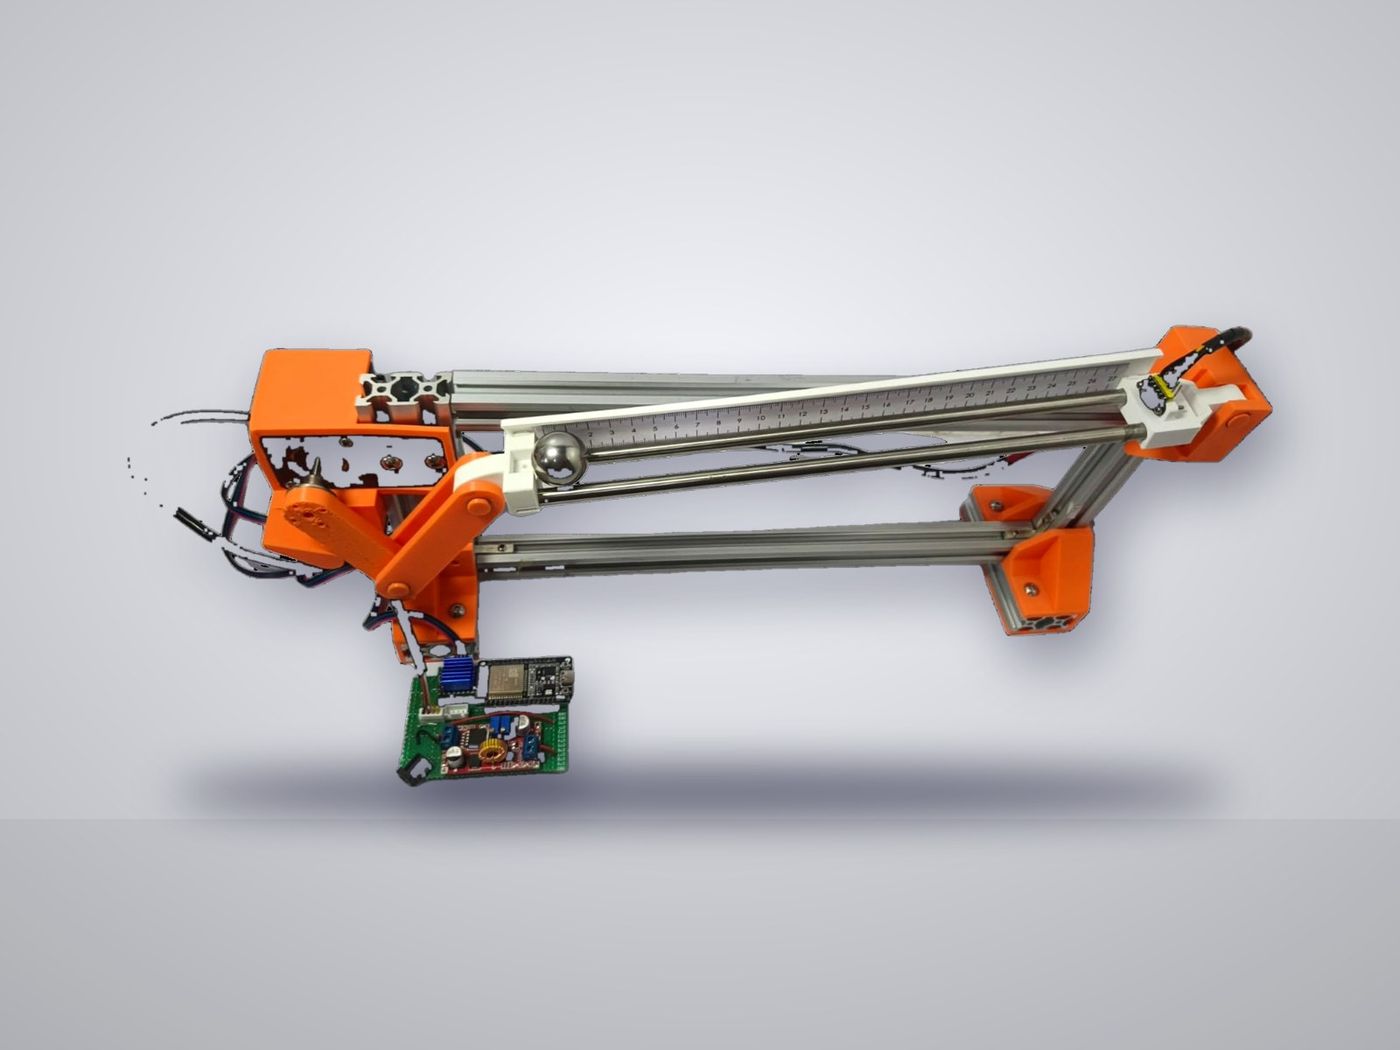
Tilt the beam, place the ball.
The gentlest of the four and the clearest for a first lesson in overshoot and settling time. A servo tilts the beam, a sensor reads the ball's position, and the loop has to stop the ball at a mark. Open-loop it is marginally stable: the ball never stops on its own.
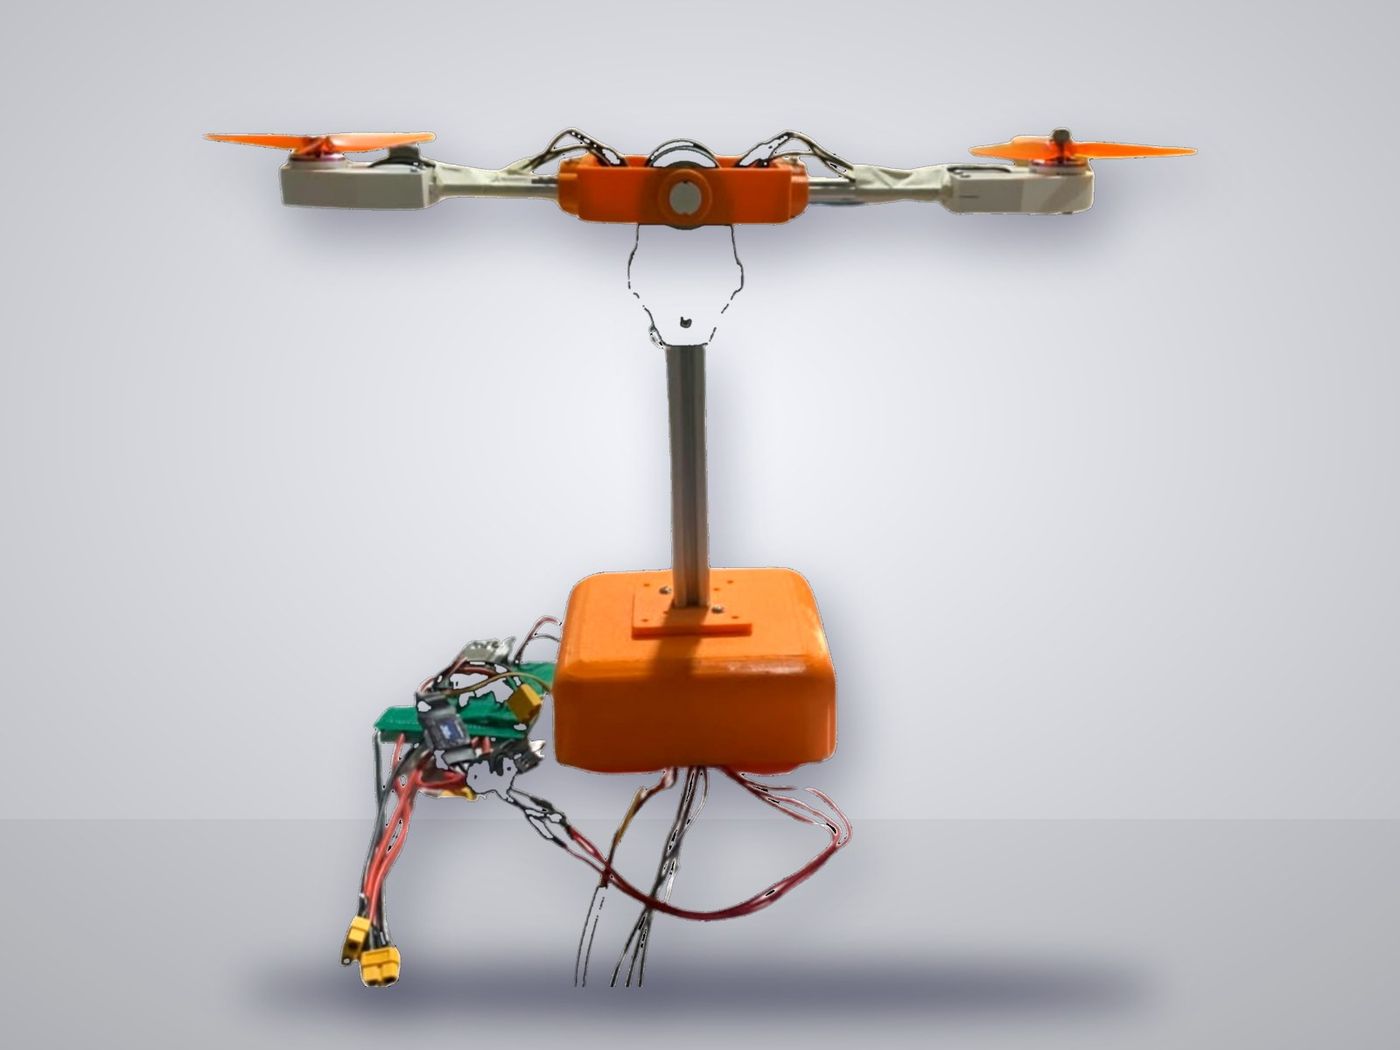
Two rotors, one beam, and the lag that makes it hard.
A twin-rotor beam that pitches on a pivot. Thrust does not change instantly, so the loop fights actuator lag as well as gravity. Good preparation for drones and any system where the actuator is slower than the plant.
One unit, complete for the lab.
- Calibrated plant, ready to use
- Controller board, PSU and cables
- Lab manual with [N] experiments and an answer key for lecturers
- Firmware source code, schematics and CAD files
- C, Python and Simulink templates
- [1-year] warranty, spare parts from Yogyakarta
IDR 20 million per unit.
Request a quote today.
Choose the plants and we will send a formal quotation, specifications and TKDN documents for procurement. Special pricing for a complete lab set.